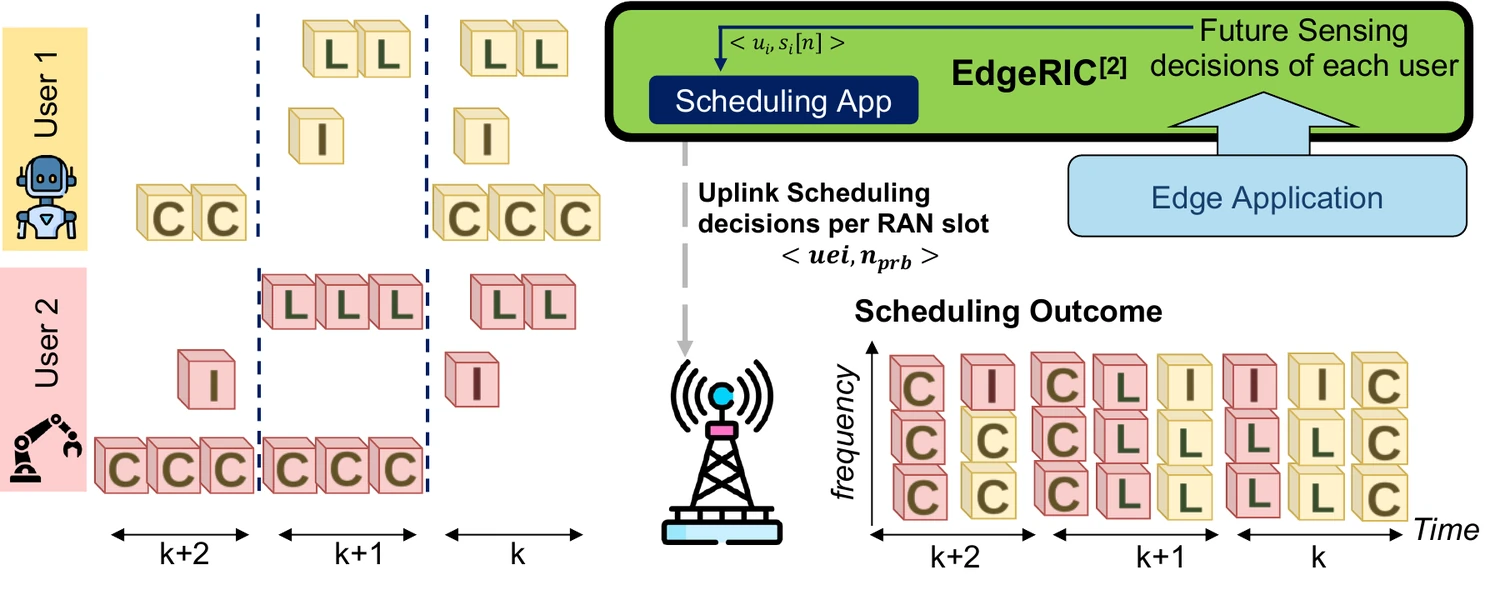
A robot's control loop can act only once every sensor stream for a timestep has arrived, and over the cellular uplink these streams arrive skewed. mmsRAN is an uplink scheduler for multimodal sensor flows that must be low latency, synchronized, and delivered in lock-step.